
Delta ASDA-E3 Basic Type AC Servo Drive User Manual 2024 – Servo Drive & ECM-E3 Motor Installation, Wiring, Tuning, Parameters & Troubleshooting PDF
Original price was: $39.95.$24.95Current price is: $24.95.
PDF user manual for Delta ASDA-E3 basic type AC servo drives and ECM-E3 servo motors, covering installation, wiring, panel operation, tuning, parameters, PR motion, Modbus, absolute system, EtherCAT and troubleshooting.
Description
File Details
- Manual type: User manual
- Brand: Delta
- Product series: ASDA-E3 basic type AC servo drive; ECM-E3 series servo motor
- Language: English
- Page count: 711 pages
- File format: PDF
- Document code: IA-ASD, ASDA-E3_UM_EN_20240108
- Edition and date: V2.0, second edition, January 2024
Chapters Covered
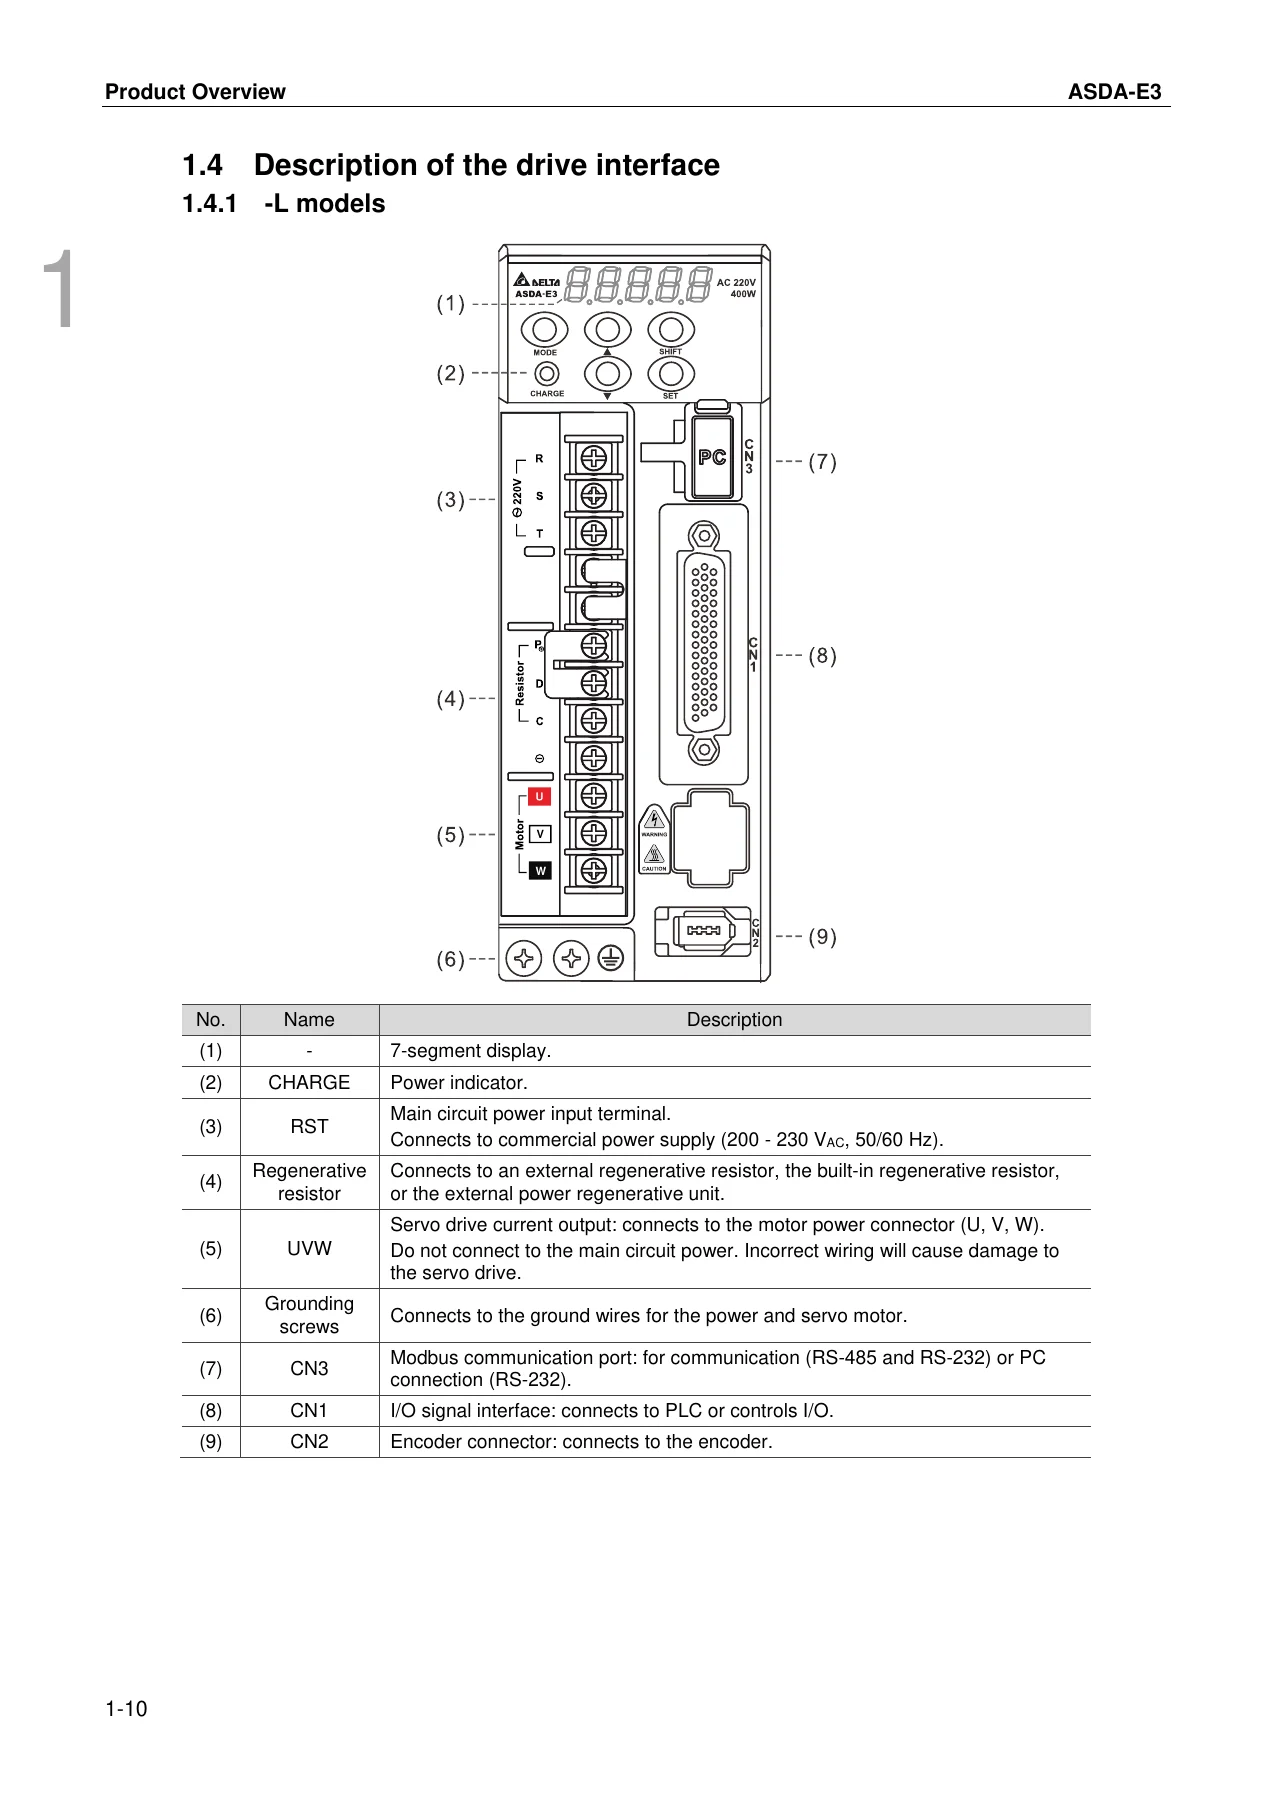
- 1 Product Overview – components of the servo set; nameplate and model explanation; ASDA-E3 drive and motor combinations; drive interface for -L and -E models.
- 2 Installation – storage and ambient conditions; mounting direction and clearances; motor handling and installation precautions; circuit breaker, magnetic contactor and fuse specifications; EMC installation and EMI filters; regenerative resistor selection; braking; cable use.
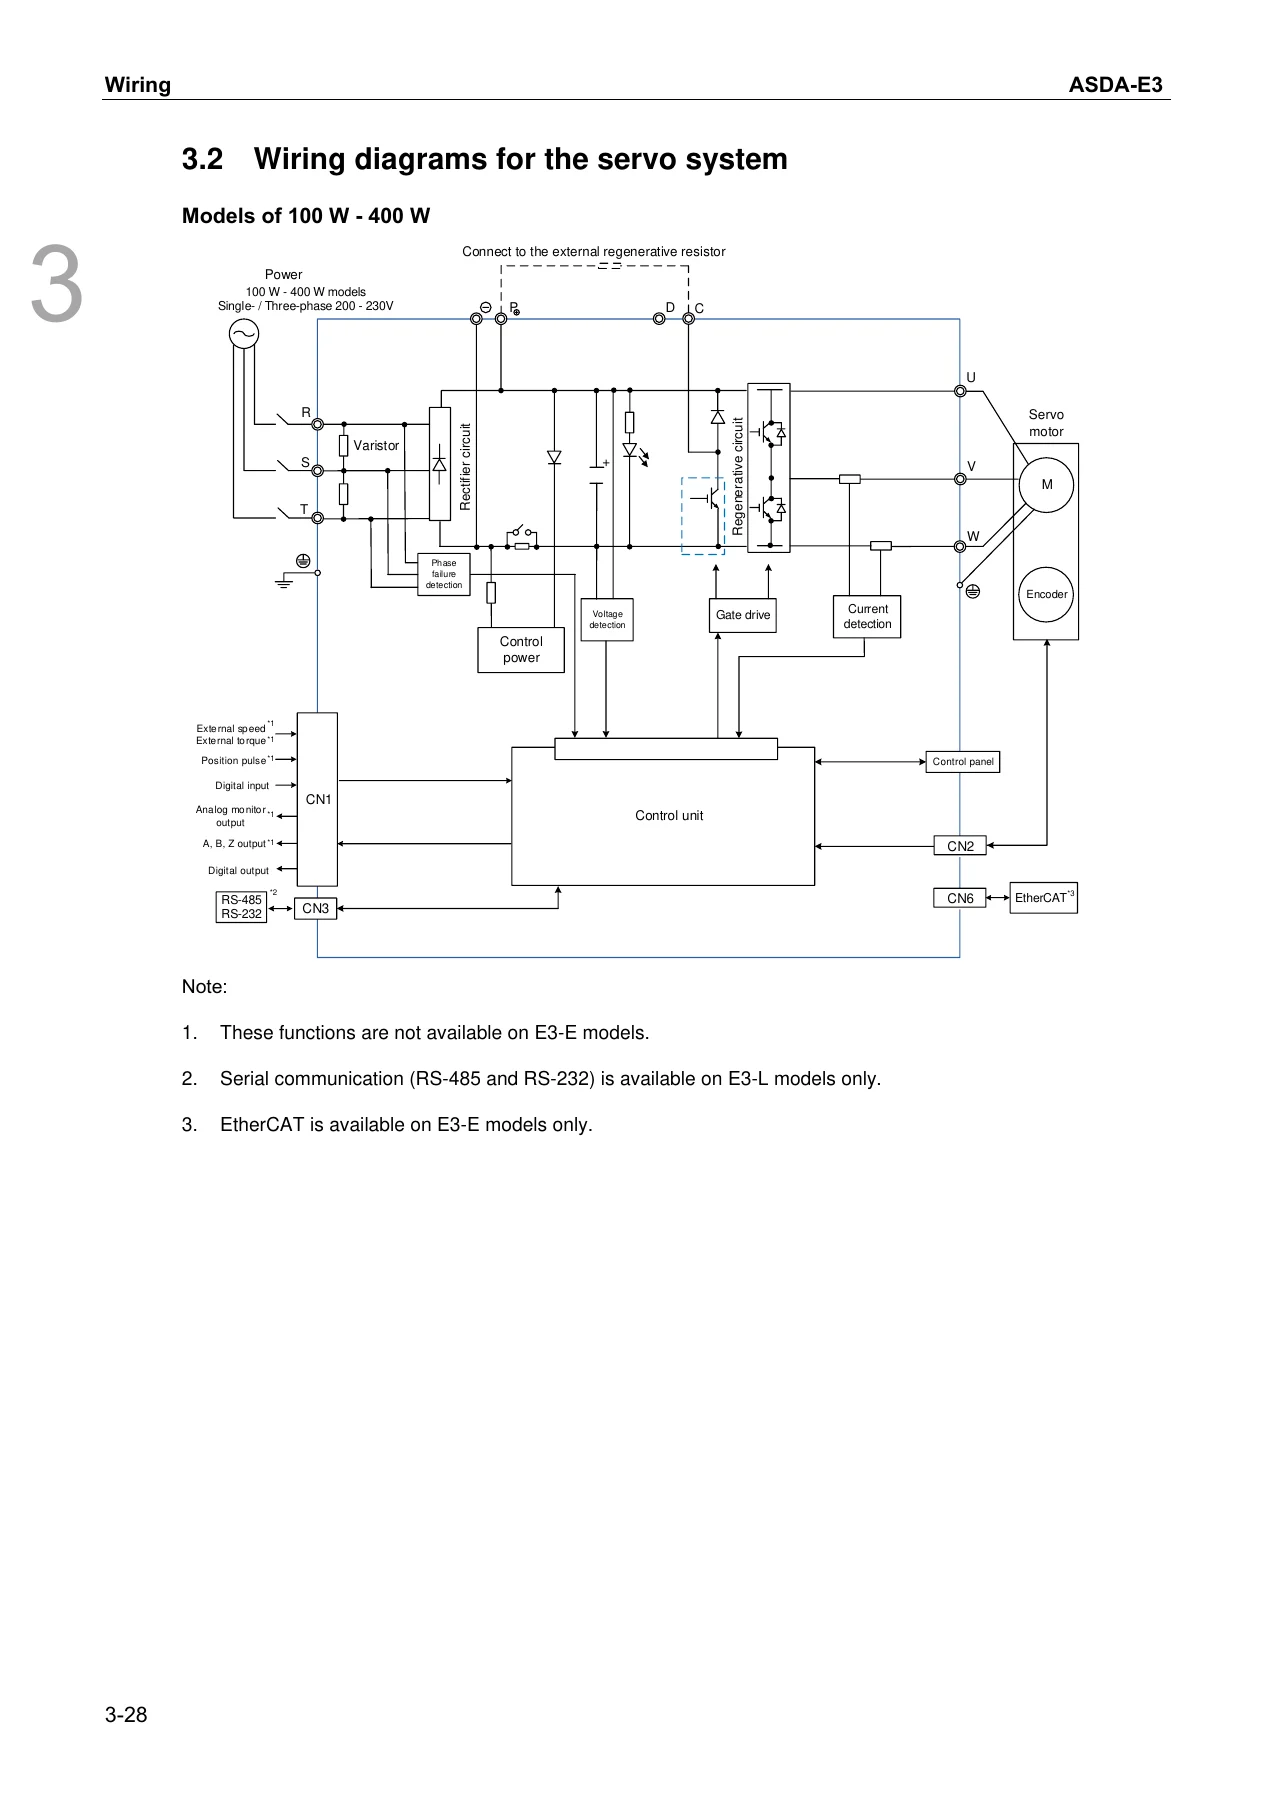
- 3 Wiring – system connection to peripheral devices; connector and terminal layout; power supply wiring; UVW power connectors for F40-F180 motors; encoder cable and connector specifications; wire selection; IP67 waterproof connectors; CN1 I/O wiring; CN2 encoder wiring; CN3 Modbus connector for -L models; CN4 Mini USB and CN6 EtherCAT for -E models; standard wiring examples for PT, PR, speed, torque and EtherCAT modes.
- 4 Test Operation and Panel Display – panel keys and display; parameter setting procedure; status and alarm display; fault record display; forced DO and DI/DO diagnosis; initial testing; power-on checks; JOG trial run without load; trial runs in Speed and Position modes.
- 5 Tuning – tuning procedure and modes; auto tuning through the panel and ASDA-Soft; gain adjustment modes; bandwidth response level and command response gain; manual gain tuning; mechanical resonance suppression.
- 6 Control Mode – control mode selection; Position mode in PT and PR forms; S-curve filter; electronic gear ratio; low-pass filter; position-loop gain adjustment; low-frequency vibration suppression; Speed mode command source, smoothing, analog scaling, timing and speed-loop gain; Torque mode command source, smoothing, analog scaling and timing; dual modes and multi-modes; speed limit and torque limit; analog monitoring.
- 7 Motion Control – PR mode description; shared PR parameters; PR monitoring variables; homing commands; speed, position, jump, write and rotary axis position commands; PR procedure overview; trigger methods; execution flow; data array handling.
- 8 Parameters – parameter definitions and list; P0 monitoring parameters; P1 basic parameters; P2 extension parameters; P3 communication parameters; P4 diagnosis parameters; P5 motion control parameters; P6 and P7 PR parameters; digital input and digital output function tables; monitoring variable descriptions.
- 9 Modbus Communication – Modbus hardware interface; communication parameters; ASCII and RTU protocol; reading and writing communication parameters; RS-485 communication specification.
- 10 Absolute System – battery box and absolute encoder cable; battery specifications and replacement; installation; system initialization; pulse number and PUU number; establishing the absolute origin with DI/DO, parameters or PR homing; reading the absolute position; related parameters, DI/DO and alarms.
- 11 EtherCAT Mode – hardware configuration; ESI file import; EtherCAT parameter settings; communication specifications; synchronization modes; EtherCAT state machine; PDO mapping; Profile Position, Profile Velocity, Profile Torque, Homing, CSP, CSV and CST modes; touch probe function; object dictionary; diagnostics and alarm list.
- 12 Troubleshooting – alarm list by general, motion control and communication type; causes and corrective actions for each alarm code.
- Appendix A Specifications – ASDA-E3 servo drive specifications and dimensions; ECM-E3 motor specifications; torque features; power derating curves; overload features; motor dimensions.
- Appendix B Accessories – power connectors and cables; encoder connectors and cables; battery box and battery cable; CN1 connector and quick connector; CN1 terminal block module; conversion cables; communication cables; optional accessories by motor frame size.
Across these chapters, the manual moves from component identification and cabinet installation through power and signal wiring, panel test runs, tuning, control-mode setup, PR motion programming, parameter descriptions, Modbus and EtherCAT communication, absolute-position setup and fault diagnosis. It is written around the ASDA-E3 drive and ECM-E3 motor set, so procedures refer to the CN1, CN2, CN3, CN4 and CN6 connectors, DI/DO planning, parameter groups P0-P7 and alarm codes rather than generic servo advice.
Model and Interface Coverage
The Delta ASDA-E3 Basic Type AC Servo Drive User Manual 2024 covers the ASDA-E3 series in -L and -E model types and the matching ECM-E3 series servo motors. The manual explains the nameplate and model code structure, shows example model combinations from 100 W through 3 kW, and identifies the practical interface differences between model types. For -L models, the CN1 I/O connector is a 44-pin interface with 9 digital inputs and 6 digital outputs, and CN3 provides Modbus communication through RS-485 or RS-232. For -E models, CN1 is a 15-pin interface with 6 digital inputs and 3 digital outputs, CN4 provides a Mini USB connection, and CN6 provides EtherCAT ports.
Important functional limits are stated in the manual: the E3-L servo drive does not support the absolute function, including the single-turn absolute function, so E3-L drives operate all motors as incremental type motors. The E3-L model also does not support PR mode. The PR mode, absolute system and EtherCAT content therefore apply to the -E models where the manual identifies that support. These distinctions matter when using the manual to match a drive to a machine, choose a control method, wire a connector or plan a communication setup.
Practical Workshop Use
This manual is arranged for hands-on work rather than a quick overview. Installation sections give mounting directions, clearance requirements and cabinet ventilation guidance. Wiring sections identify terminal names, connector pin assignments, cable types, shielding practices and standard connection examples. Test operation sections describe panel navigation, JOG runs without load and trial runs in Speed and Position modes. Tuning sections explain auto tuning, gain adjustment modes and manual gain parameters, with notes on resonance suppression and bandwidth.
For programming and setup work, the manual provides PR path configuration, homing methods, position and speed command structures, electronic gear ratio settings and parameter group descriptions. Communication sections cover Modbus RTU and ASCII details, RS-485 wiring, EtherCAT state machine behavior, PDO mapping and object dictionary entries. The absolute system chapter explains battery handling, absolute origin establishment and position reading. The troubleshooting chapter lists alarm codes with causes and corrective actions, making it useful during commissioning and fault finding.
Put the Delta ASDA-E3 Manual to Work
This PDF gives technicians a single reference for commissioning and maintaining ASDA-E3 basic type servo drives with ECM-E3 motors: checking nameplate and model combinations, planning cabinet clearances, selecting circuit breakers and cables, wiring CN1, CN2, CN3, CN4 and CN6, performing JOG and no-load trials, tuning with auto and gain-adjustment modes, building PR paths, reading P0-P7 parameters, setting up Modbus or EtherCAT, establishing an absolute origin, and tracing alarms to corrective actions. Having the correct connector pinouts, parameter ranges, timing diagrams and alarm tables on hand reduces guesswork when a drive is being installed or a machine is down.
IMAGES PREVIEW
Delivered as an instant PDF download after payment; no shipping and no waiting for a physical book. The file can be opened on a laptop, tablet or phone and selected pages can be printed for the workshop bench.
Reviews
There are no reviews yet.